Unitree G1 EDU | U1-U14 | Plataformas de desarrollo humanoides

Variantes: EDU-U5 | Ultimate C
Plataformas de desarrollo Unitree G1
Las plataformas de desarrollo Unitree G1 Edu, así como las variantes Professional y Ultimate, son sistemas de robots humanoides diseñados para la investigación, el desarrollo y la robótica específica de cada aplicación. El desarrollo secundario de alto y bajo nivel, un SDK, algoritmos de IA y un dock de expansión de 100 TOPS permiten crear aplicaciones propias. Según el modelo base, se dispone de 23 o 29 grados de libertad. Las variantes Professional y Ultimate complementan la plataforma con soluciones de agarre y manos preconfiguradas, algunas de ellas con sensores táctiles y cámaras RGB en la muñeca. Esto permite, en particular, desarrollar y probar aplicaciones de agarre, manipulación e IA.
Nuestros destacados
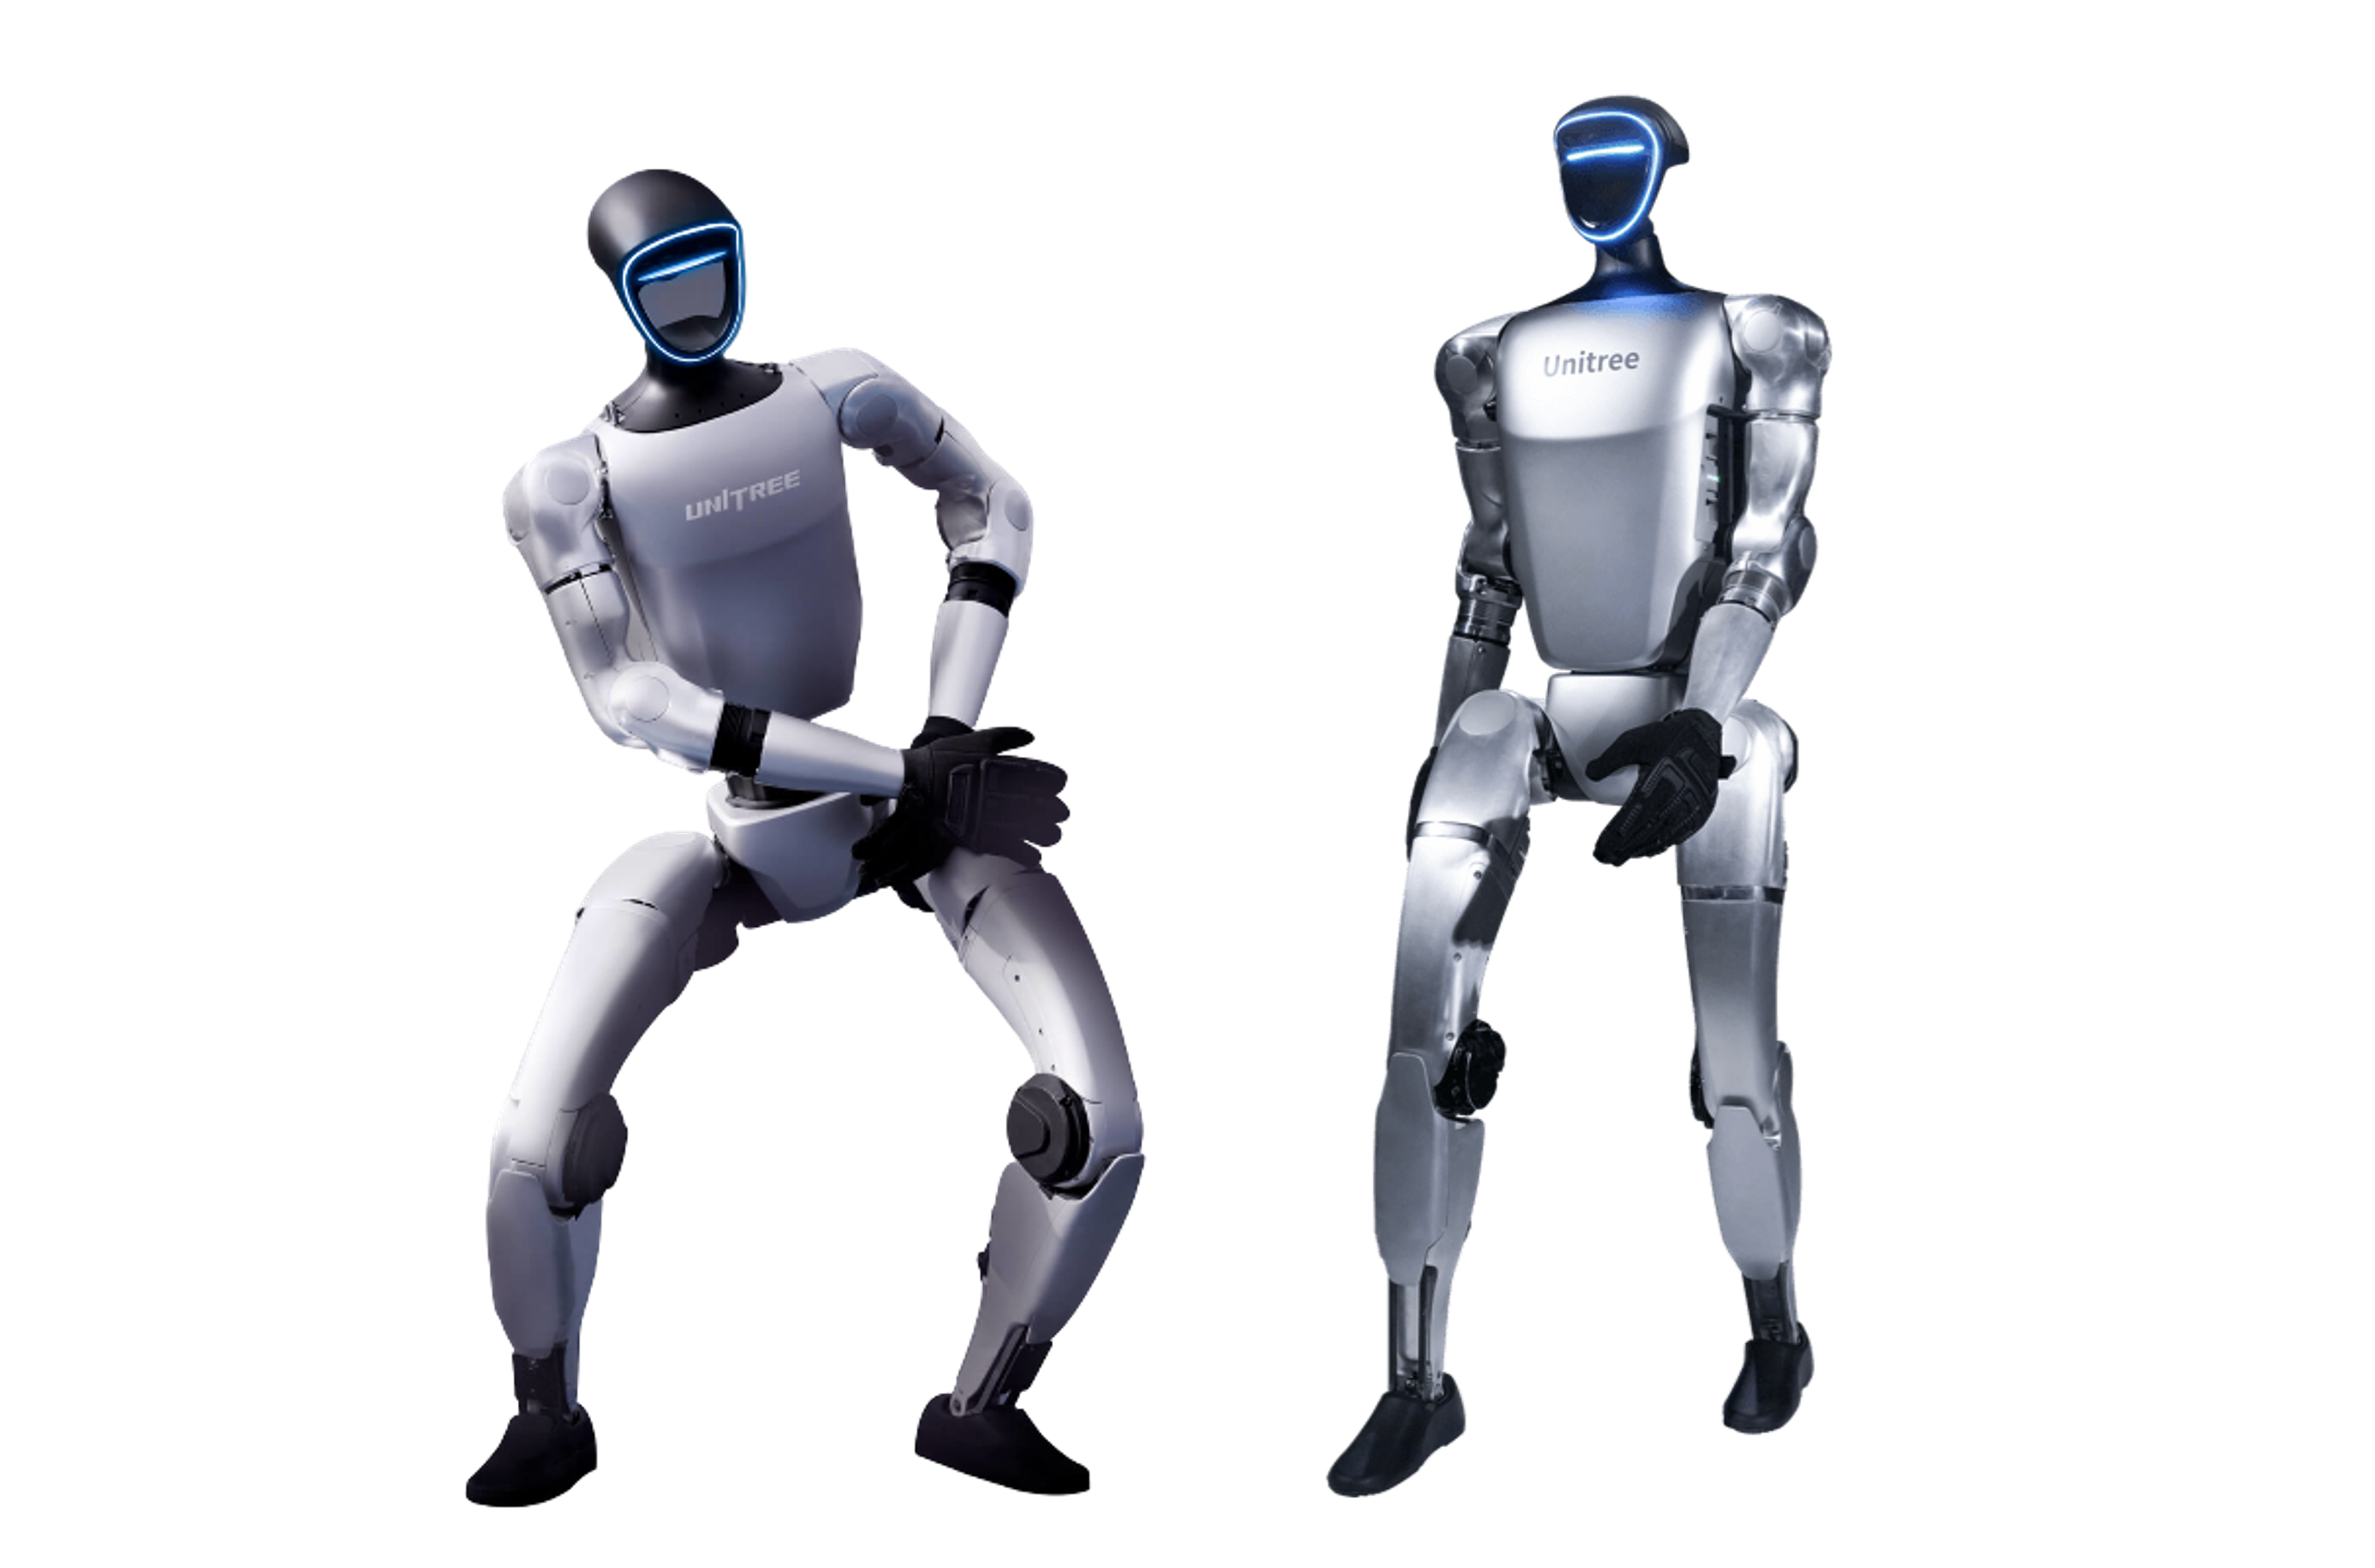
The differences between the development platforms
G1 EDU Standard | 23 DOF | basis of the Professional variants --> Dummy Hand | EDU-U1
G1 EDU Plus | 29 DOF | basis for Ultimate variants --> Dummy Hand | EDU-U2
G1 EDU- Professional (23 DOF Basis)
Professional A → Dex3-1 | 3 Finger | EDU-U9
Professional B → Dex3-1 | 3 Finger with tactile sensors | EDU-U10
Professional E → BrainCo Revo 2 Basic | 5 Finger | EDU-11
Professional F → BrainCo Revo 2 Touch | 5 Finger with tactile sensors | EDU-12
Professional G → Dex2/5 | 5 Finger | EDU-14
Professional H → Dex1-1 Gripper Plus
Professional I → Wuji Hand 2 | 5 Finger
G1 EDU- Ultimate (29 DOF Basis)
Ultimate A → Dex3-1 | 3 Finger | EDU-U3
Ultimate B → Dex3-1 | 3 Finger with tactile sensors | EDU-U4
Ultimate C → Inspire DFQ | 5 Finger | EDU-U5
Ultimate D → Inspire E2 | 5 Finger | with tactile sensors | EDU-U6
Ultimate E → BrainCo Revo 2 Basic | 5 Finger | EDU-U7
Ultimate F → BrainCo Revo 2 Touch | 5 Finger with tactile sensors | EDU-U8
Ultimate G → Dex2/5 | 5 Finger | EDU-13
Ultimate H → Dex1-1 Gripper Plus
Ultimate I → Wuji Hand 2 | 5 Finger
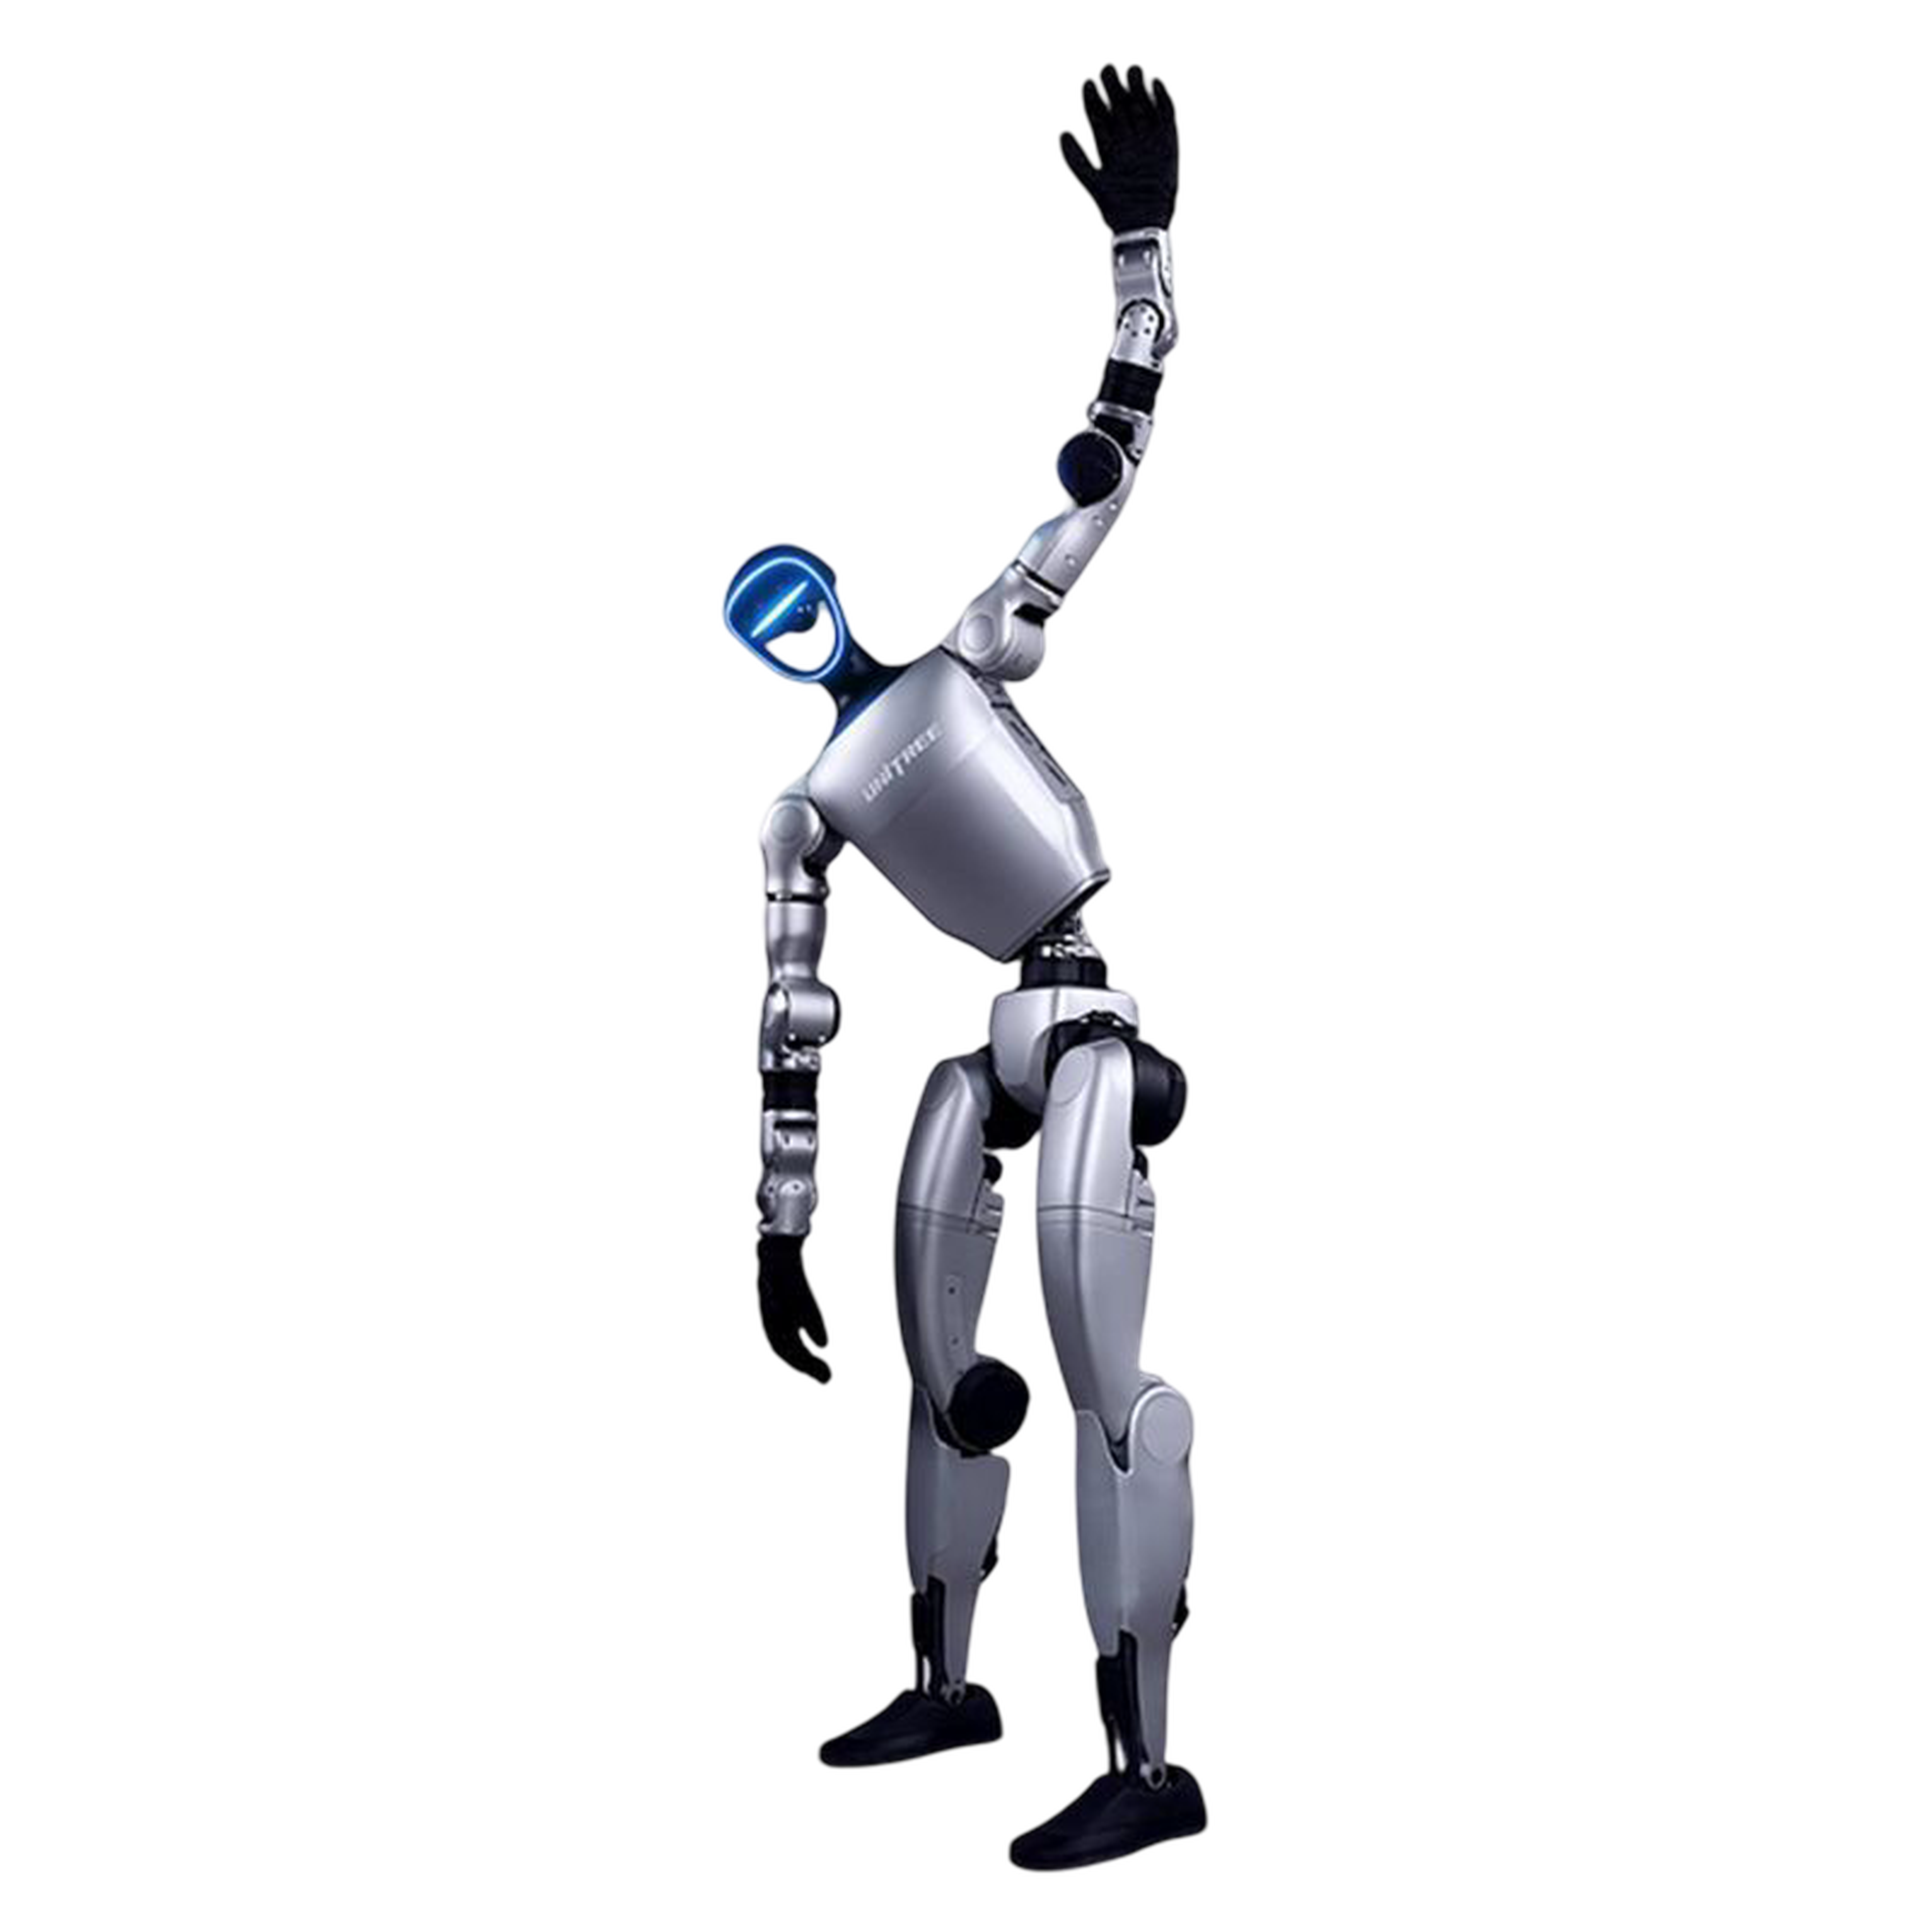
Humanoid Development Platform Unitree G1 EDU U5
The Unitree G1 EDU U5 is a 1,270 mm tall humanoid development platform for research, education, and advanced robotics projects. Weighing around 35 kg, the robot is suitable for laboratory and demonstration setups. The replaceable 13S smart battery provides approximately two hours of operation, depending on motion and computing load. A depth camera and 3D LiDAR provide environmental data for perception, navigation, and autonomous experiments. Dual encoders at the joints, internal cable routing, and local air cooling support repeatable motion. Knee joints with up to 120 Nm of torque and an arm payload of up to 3 kg provide the foundation for dynamic motion sequences, grasping experiments, and mobile manipulation. The payload and motion profile must be adapted to the experimental setup.
Inspire DFQ Five-Finger Hands on the Unitree G1 EDU U5
The G1 EDU U5 is configured with Inspire DFQ five-finger hands without tactile sensing. Each hand features six active degrees of freedom and twelve joints. The five fingers enable a wide range of grasping patterns and are suitable for experiments with objects of different shapes. Repeatability is ±0.20 mm; gripping force is 6 N at the thumb and 4 N at each of the other fingers. Four-finger flexion of up to 570°/s enables fast opening and closing movements. Wrist-mounted RGB cameras provide image data for object detection, grasp point detection, and vision-guided manipulation. Since the hands do not feature tactile sensing, contact and gripping force must be controlled through the control system, known object characteristics, and appropriate motion limits.
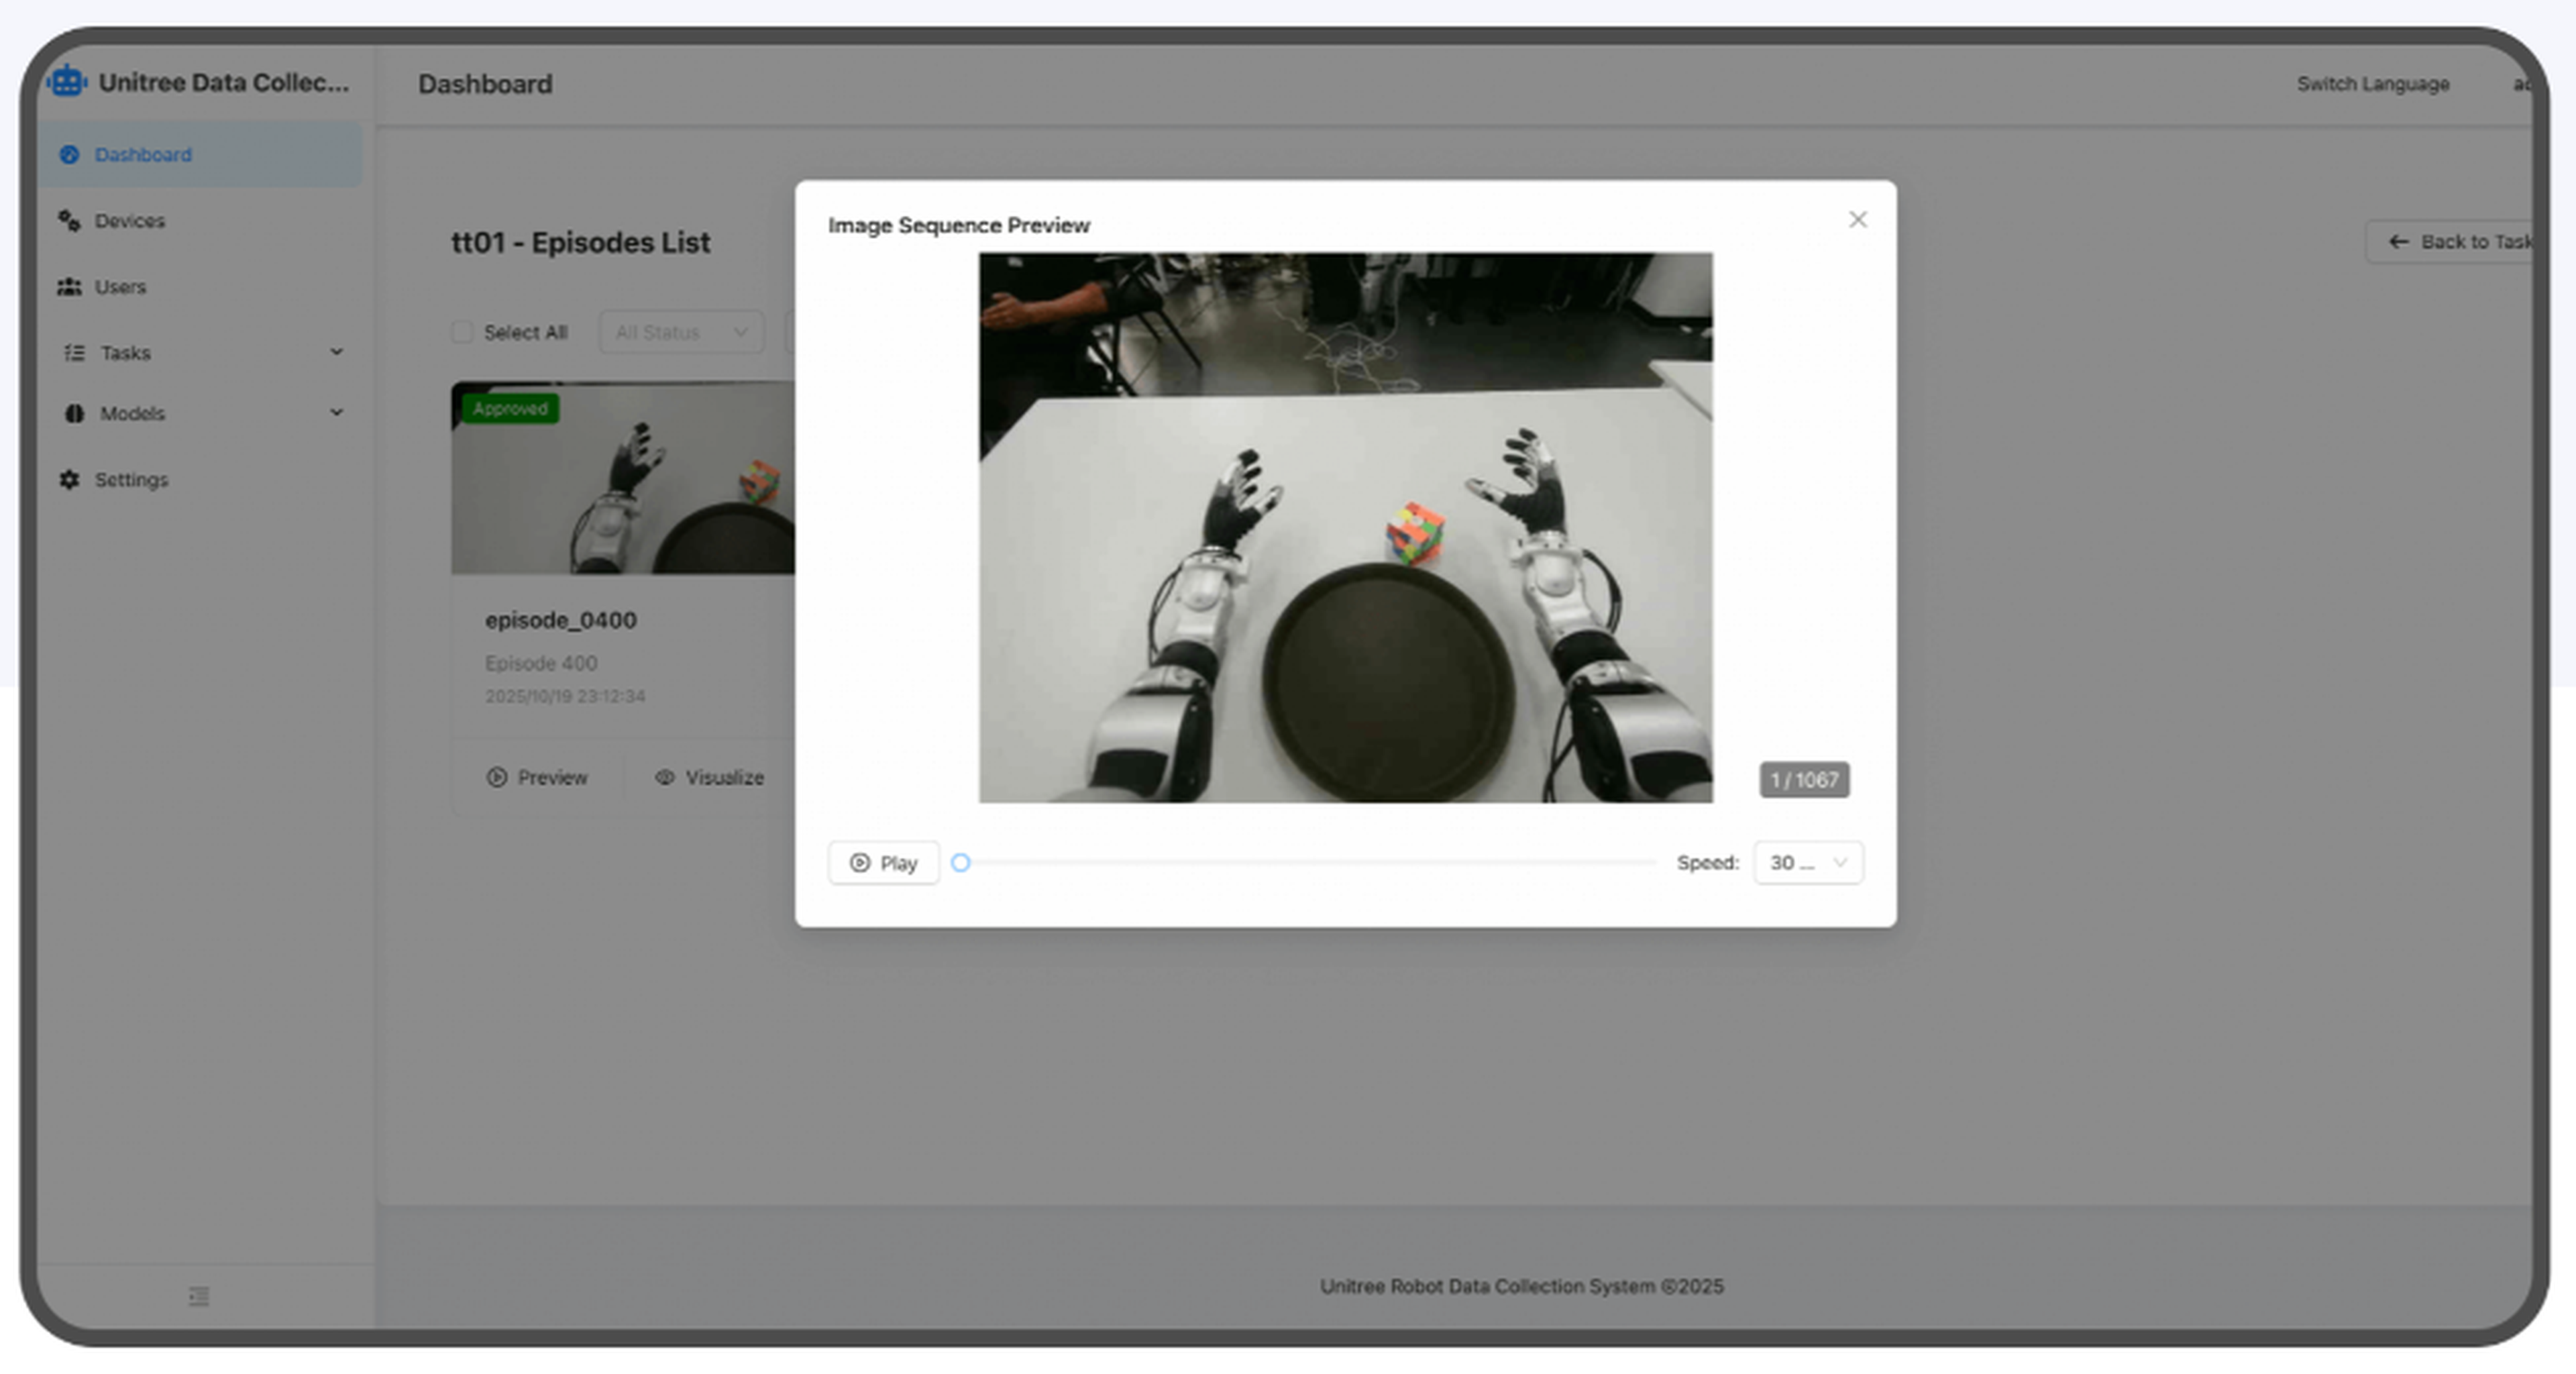
Control and Programming the G1 EDU platform
The G1 EDU platform provides high-level and low-level interfaces for custom applications. Developers can implement motion sequences, joint-level control tasks, and manipulation processes. The integrated expansion dock with up to 100 TOPS is suitable for AI algorithms, machine vision, navigation, and positioning. Wi-Fi 6 and Bluetooth 5.2 facilitate integration into laboratory environments, while Smart OTA supports system updates. When programming the Inspire DFQ hands, finger positions and wrist camera data can be integrated into object planning. This enables vision-guided grasping sequences for objects of different shapes. Control cycles, force limits, collision zones, and abort conditions must be defined for the specific project and tested before operation.
Secondary Development and Applications
The open EDU version supports secondary development and is suitable for projects that go beyond predefined motions. Typical areas include humanoid locomotion, balance control, AI-based perception, navigation, human-robot interaction, and manipulation. Universities can use the robot for computer science, mechatronics, control engineering, and machine learning. Companies can conduct feasibility studies for inspection, teleoperation, service tasks, or handling lightweight objects. Hands and grippers available depending on the specific variant further expand the range of experimental applications. Since the G1 is classified as a research and educational platform or partly completed machinery, a risk assessment, safety concept, and application-specific integration are required.
Training, Accessories, and Integration provided by RBTX
RBTX supports users in selecting the Unitree G1 EDU U5 and setting up a complete, functional robotics system. This includes training for operation, commissioning, and programming, as well as selecting accessories, end effectors, sensors, and safety components. For development projects, RBTX can support the coordination of the robot, software, network, computing hardware, and experimental setup. Integration focuses on interface validation, defining system functions, and involving suitable integration partners. This helps determine at an early stage which components are required for a demonstrator, research project, or proof of concept. Safety requirements, responsibilities, and acceptance criteria are considered from the outset based on the intended application.
Sistemas económicos creados con RBTX
Concierte una videollamada gratuita con nuestros expertos


